Selected research themes

Evaluating and learning decision policies
How can one evaluate and even learn new decision policies using data from past decisions?
-
“Learning Pareto-Efficient Decisions with Confidence”.
S. Ek, D. Zachariah, and P. Stoica.
International Conference on Artificial Intelligence and Statistics, 2022, pp. 9969–9981
-
“Off-Policy Evaluation with Out-of-Sample Guarantees”.
S. Ek, D. Zachariah, F. D. Johansson, and P. Stoica.
Transactions on Machine Learning Research, 2023
-
“Externally Valid Policy Evaluation from Randomized Trials Using Additional Observational Data”.
S. Ek and D. Zachariah.
The Thirty-eighth Annual Conference on Neural Information Processing Systems, 2024
-
“Persistence to antihypertensive drug classes in uncomplicated hypertension: a nationwide Swedish cohort study”.
K. Laurell, S. Gustafsson, E. Lampa, D. Zachariah, S. Ek, K. Rådholm, M. Martinell, and J. Sundström.
EClinicalMedicine, vol. 91, 2026

Data-driven control
How can controllers for dynamical systems be constructed from empirical data?
-
“On the regularization in DeePC”.
P. Mattsson and T. B. Schön.
IFAC-PapersOnLine, vol. 56, no. 2, pp. 625–631, 2023
-
“Learning state observers for recurrent neural network models”.
F. Bonassi, C. Andersson, P. Mattsson, and T. B. Schön.
63rd IEEE Conference on Decision and Control (CDC), 2024
Adaptive design for dynamical systems
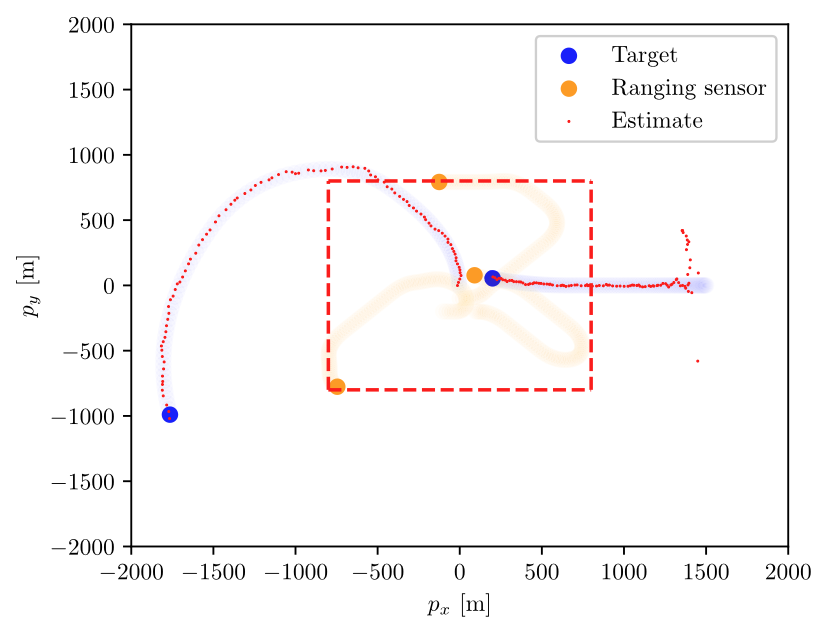
How should inputs to dynamical systems be design to yield maximal information of interest?
-
“Target tracking using robust sensor motion control”.
J. Hu, D. Zachariah, and P. Stoica.
Signal Processing, p. 110341, 2025
-
“Adaptive Experiment Design for Nonlinear System Identification With Operational Constraints”.
J. Hu, D. Zachariah, T. Wigren, and P. Stoica.
IEEE Signal Processing Letters, vol. 33, pp. 151–155, 2025